Key takeaway
- AI in autonomous driving for enterprise leaders: where AI fails, safety evidence, NHTSA and UN rules, a safety case checklist and a 3 to 5 year outlook.
AI in autonomous driving is the set of perception, prediction and planning models that let a vehicle perform the driving task, and the safety case and regulation that decide whether it may do so on public roads. For an enterprise this is a risk and evidence problem as much as a technology one. According to NHTSA, no fully automated vehicle is currently for sale to US consumers and every vehicle on sale needs the driver's full attention, so the real decisions sit in fleets, pilots and supplier programmes. This guide takes the safety and regulatory angle; for the levels of automation and ADAS, read our guide to ADAS and autonomous vehicles.
The short answer for leaders: judge an AI driving system by its operational design domain, the evidence behind it and the controls around it, not by the demo. The regulatory picture changed in 2026 with new UN rules for driverless systems, while US oversight rests on crash reporting and vehicle safety standards. Below we cover where AI fails, what the evidence shows, which rules apply, what a safety case contains and how to sequence adoption. For the in-vehicle compute side, see Edge AI for autonomous vehicles and edge AI agents in the automotive industry.
How does AI drive a vehicle, and where can it fail?
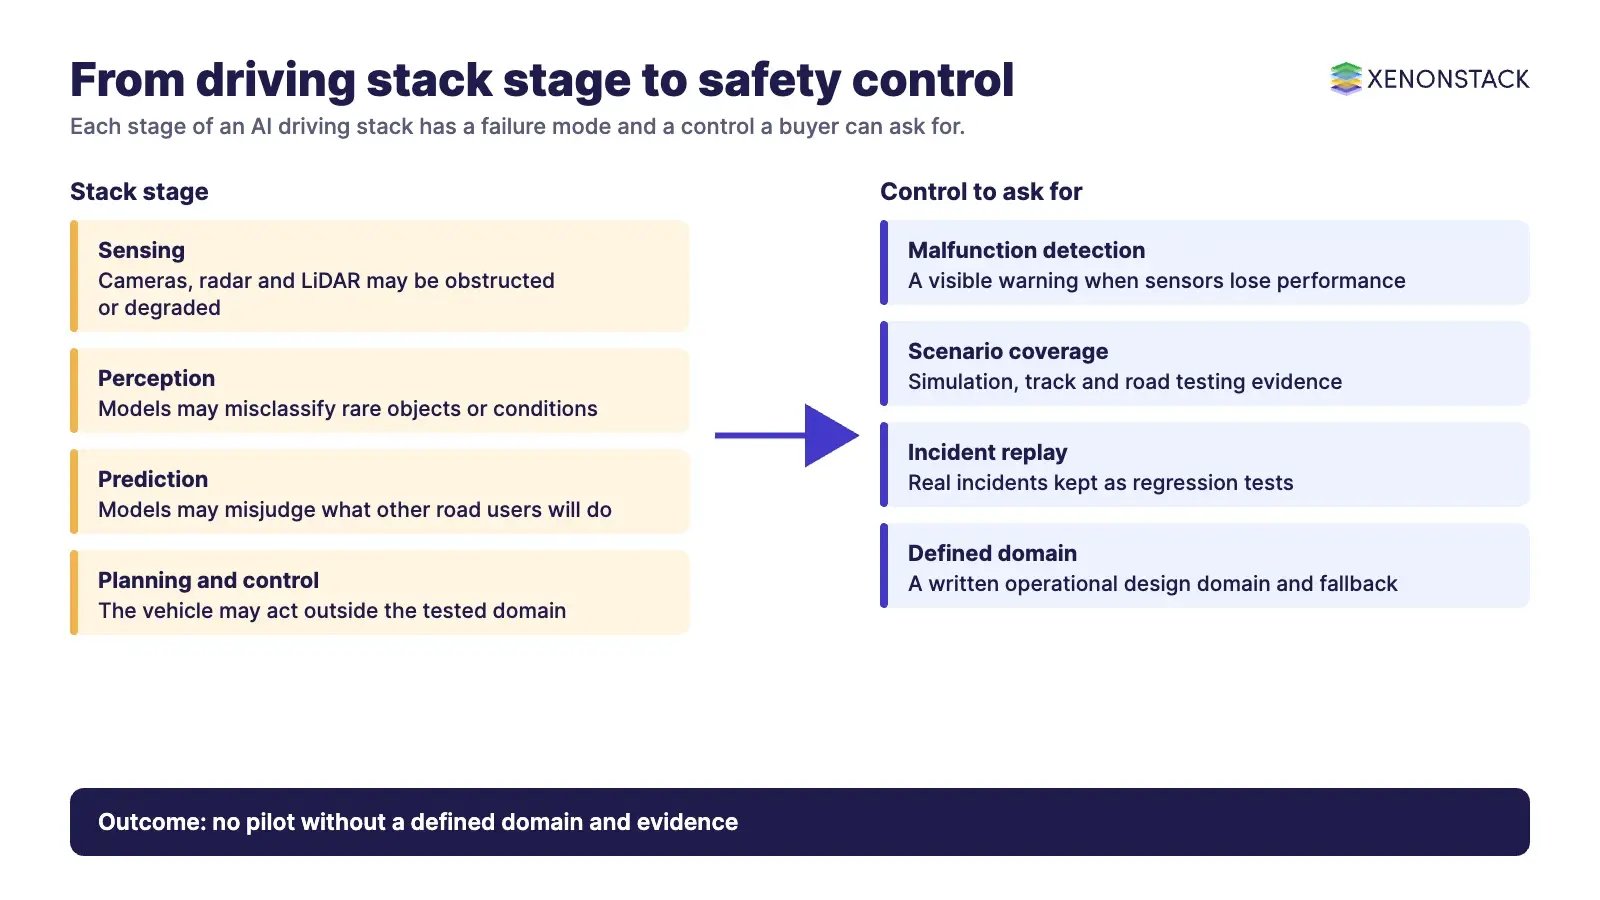
An autonomous driving stack turns sensor data into vehicle actions in stages. Each stage has its own failure mode and its own control. The table below is our engineering view of the stack, not a standard.
| Stage | What the AI does | Typical failure mode | Control to ask for |
|---|---|---|---|
| Sensing | Cameras, radar and LiDAR capture the scene | Obstructed or degraded sensors | Malfunction detection and a visible warning to the driver |
| Perception and localisation | Models detect objects and place the vehicle on a map | Misclassification of rare objects or conditions | Scenario coverage in simulation, track and road testing |
| Prediction | Models estimate what other road users will do next | Wrong assumption about intent | Replay of real incidents as regression tests |
| Planning and control | Selects a path and commands steering, speed and braking | Unsafe action outside the tested domain | A defined operational design domain and a fallback behaviour |
| Monitoring | Logs decisions and reports incidents | Gaps that stop root-cause analysis | In-service monitoring and stored safety data |
Computer vision sits at the heart of the perception stage; our guide to computer vision applications covers the techniques. Real-time inference usually runs in the vehicle, which is why edge computing matters for latency-critical decisions, and connectivity is covered in 5G for automated ground vehicles.
What does the safety evidence actually show?
Safety claims for AI driving differ sharply by level. Evidence for driver assistance (Levels 0 to 2) and for driverless robotaxis (Level 4) should not be mixed. The sources below are the ones we would put in front of a risk committee.
| Evidence | What it says | Who published it | How to read it |
|---|---|---|---|
| Driverless operator data | Through June 2026, Waymo reports 271.3 million rider-only miles across Phoenix, the San Francisco Bay Area, Los Angeles, Austin and Atlanta, with 95% fewer serious-injury-or-worse crashes and 82% fewer any-injury crashes than its human benchmark | Waymo safety impact page | Operator's own data, using a benchmark it describes; no snowfall in its current cities |
| Independent study of robotaxis | During driverless operation, Waymo's police-reportable crash rate was 68% lower and its injury crash rate 81% lower than human drivers in the same cities and years (Teoh et al., 2026) | IIHS | Independent, but limited to one operator and its cities |
| Partial automation (Level 2) | A 2025 study found no crash-reduction advantage for partial automation over crash-avoidance technology alone; regular users often hold a false sense of security | IIHS | Treat Level 2 as driver assistance with a monitoring duty |
| Consumer availability | Level 3 to 5 technologies are not available for consumer purchase | NHTSA | Enterprise exposure is mostly through fleets, suppliers and pilots |
The pattern is consistent: strong results for narrow, geofenced, driverless service, and no proven advantage from letting drivers disengage in partial automation. Neither result transfers automatically to a new city, vehicle or weather condition, so any programme needs its own evidence.
Which rules apply to AI driving systems?
There is no single global rulebook yet. The table lists the instruments an enterprise is most likely to meet, with their current status according to the sources we read. This is not legal advice; confirm the position with counsel and the regulator in each market.
| Instrument | What it covers | Current status | Source |
|---|---|---|---|
| US federal oversight | NHTSA oversees safe testing, development and deployment of automated driving systems; manufacturers must comply with Federal Motor Vehicle Safety Standards | Testing is limited to restricted locations and conditions; a 2025 USDOT framework and exemption programme exist | NHTSA |
| Standing General Order | Crash reporting for automated driving systems and Level 2 driver assistance | Third amended order issued 24 April 2025, effective 16 June 2025; the most severe crashes are reported within five days | Standing General Order |
| FMVSS No. 127 | Automatic emergency braking, pedestrian braking and forward collision warning on light vehicles | Final compliance date 1 September 2029 for all vehicles; 1 September 2030 for small-volume manufacturers | Federal Register notice for FMVSS No. 127 |
| UN regulation on driverless systems | Safety case, safety management system, validation, in-service monitoring and data storage for ADS | Adopted by WP.29 on 24 June 2026; as reported by Connected Automated Driving, entry into force was expected about a month later | Connected Automated Driving |
| UK Automated Vehicles Act 2024 | Domestic regime for authorisation and operator licensing | As reported by Shoosmiths, secondary legislation and guidance are the next steps and the UK is expected to align with the UN approach | Shoosmiths |
| General AI risk management | Voluntary framework: Govern, Map, Measure, Manage | AI RMF 1.0 released 26 January 2023 | NIST AI Risk Management Framework |
What does a safety case for an AI driving system contain?
The new UN regulation is built around a safety case. As reported by Shoosmiths, the framework has six pillars. We map each to the evidence an enterprise buyer or fleet operator should ask a supplier for.
| Pillar (as reported) | What to ask for |
|---|---|
| Performance within the operational design domain | A written domain definition and results for the full driving task inside it |
| Safety management system across the lifecycle | Named owners, change control for model updates and post-deployment review |
| Approval based on a structured safety case | The argument and the evidence, not a summary slide |
| Validation by simulation, controlled testing and real-world data | Coverage reports for each of the three, including how simulators were validated |
| In-service monitoring and incident reporting | Incident rates, near-miss data and the reporting route to the regulator |
| In-vehicle data storage | What is recorded, for how long and who can access it |
The same sources report the safety bar: the system must reach a level at least equal to a competent human driver. That is a regulatory statement of intent, and meeting it still has to be shown with evidence for each domain, as Connected Automated Driving describes.
What governance, security and cost issues apply?
Governance starts with decision records. Every automated action that affects safety needs a trace that links the model version, the input, the policy in force and the outcome, otherwise incident review and regulator reporting are slow and contested. NexaStack describes itself as an agentic operating platform for physical AI that runs across on-premises, cloud and hybrid environments, and AgentGRC keeps autonomous agent actions inside policy, with the audit trail risk teams need, according to its site. The ideas in agentic AI risk management apply directly: limit what an agent may do, who approves it and how each action is recorded.
| Area | Question to settle | Why it matters |
|---|---|---|
| Model change control | Who approves a model or map update before it reaches vehicles? | A new version can change behaviour in the tested domain |
| Data and logging | Which events are stored and for how long? | Supports incident analysis and regulatory reporting |
| Cybersecurity | Who owns security for sensors, connectivity and over-the-air updates? | A compromised update path affects every vehicle on it |
| Cost | What is the cost of validation, simulation and monitoring per domain? | Evidence collection often costs more than the model work |
| Liability and insurance | Who is responsible when the system is driving? | Responsibility shifts at higher levels; confirm contracts and cover |
Which technology trends are changing the stack?
Two shifts matter for safety teams. First, end-to-end learned driving models take raw sensor data and output driving actions. They can simplify the stack, yet they make it harder to explain a decision, so testing and traceability must be stronger rather than weaker. Second, multimodal and generative models are being explored for scene understanding and for creating test scenarios. Treat both as areas to pilot with evidence gates, not as proven. We have not cited vendor-specific claims here because we could not confirm them from the vendors' own pages.
What are the trade-offs, and when should you not go further?
| Situation | Recommendation | Reason |
|---|---|---|
| Supplier cannot define its operational design domain | Do not proceed to a pilot | Safety evidence has no boundary to attach to |
| Evidence comes from another city or climate | Run local validation first | Benchmarks are reweighted to where an operator drives; snow is not represented in current data |
| Level 2 system marketed as self-driving | Keep driver monitoring and training in place | Partial automation never replaces the driver |
| No incident reporting route | Pause | Regulators in several regions expect reporting and monitoring |
| Model updates shipped without change control | Pause | Behaviour can change outside the tested domain |
How should an enterprise sequence adoption?
| Step | Action | Exit criterion |
|---|---|---|
| 1. Define the use case | Pick one route, site or duty cycle and its operational design domain | Domain written and signed off |
| 2. Map the rules | List NHTSA, state, UN and local requirements for that use case | Legal and risk review complete |
| 3. Ask for the safety case | Request the evidence listed above from the supplier | Gaps logged with owners |
| 4. Pilot with monitoring | Run supervised operation with incident logging | Incident and near-miss data reviewed on a fixed cadence |
| 5. Expand by domain | Add routes, weather or vehicles one at a time | New evidence for each addition |
What will change in AI-driven autonomous driving over the next 3 to 5 years?
The table separates what the sources show from our own view. Dates are those stated by the sources; the outlook column is our judgement.
| Area | What the sources show | Our outlook (view) |
|---|---|---|
| UN rules for driverless systems | Adopted by WP.29 on 24 June 2026, endorsed by Canada, China, the EU, Japan, the UK and the US, as reported by Connected Automated Driving; the FIA says real-world performance should be monitored after deployment | Type approval routes built on the safety case begin to appear in national law; FIA also expects the framework to evolve as evidence builds |
| US vehicle standards | FMVSS No. 127 compliance by 1 September 2029 (2030 for small-volume makers) | Emergency braking becomes a baseline feature, so Level 2 differentiation shifts to driver monitoring |
| US crash reporting | Standing General Order covers ADS and Level 2 crashes with five-day reporting for the most severe | Public incident data keeps feeding independent studies |
| Driverless service footprint | Five US metro areas in the Waymo data through June 2026 | Growth city by city, each needing local validation; snow and complex weather are the open test |
| Consumer availability | Level 3 to 5 not available for consumer purchase today | Consumer Level 4 within five years is unlikely; fleet and geofenced service lead |
To connect the vehicle, edge and governance layers in one programme, see NexaStack for physical AI operations and ElixirData Context OS for governed context and decision traces; for agent automation around the programme, see ElixirClaw.
To map one driving decision your AI should make, and the context and policy it depends on, book a Context Workshop. See what happens in the workshop.
Frequently asked questions
What is AI in autonomous driving?
It is the set of perception, prediction and planning models that perform the driving task, together with the safety evidence and controls that allow the system to operate. Responsibility and approval depend on the automation level.
Can I buy a self-driving car today?
According to NHTSA, no fully automated vehicle is currently for sale to US consumers, and every vehicle sold requires the driver's full attention at all times. Level 3 to 5 technologies are not available for consumer purchase.
Is driverless operation safer than human driving?
The Waymo safety page reports 95% fewer serious-injury-or-worse crashes and 82% fewer any-injury crashes than its human benchmark through June 2026, and an IIHS study found a 68% lower police-reportable crash rate. Both relate to one operator in its own cities, so local validation is still needed.
What does the Standing General Order require?
Identified manufacturers and operators must report certain crashes involving automated driving systems or Level 2 driver assistance. Under the third amended order, the most severe crashes are reported within five days and less severe ones monthly.
What did the UN adopt for driverless vehicles in 2026?
As reported by Connected Automated Driving, WP.29 adopted a regulation on 24 June 2026 requiring a safety case, a safety management system, validation by simulation, track and road testing, in-service monitoring and data storage, with safety at least equal to a competent human driver.
What does the next 3 to 5 years look like for driverless regulation?
Sourced dates point to UN rules moving into national approval routes and FMVSS No. 127 becoming mandatory by 1 September 2029. Our view is that driverless service will grow city by city, with local evidence needed each time.
Follow XenonStack on LinkedIn: XenonStack on LinkedIn for new guides on agentic AI, data and platform engineering.
Explore the XenonStack platform family: ElixirData · ElixirClaw · ElixirHub · NexaStack · MetaSecure · Neural AI · AgentGRC · AgentSRE · AgentAnalyst · AgentInstruct · AgentRAI · AgentScrum · AgentSearch · AgentForce · AI Aviator · SAIF Aviator · CohortIQ · XenonStack AI · XenonStack UAE